


Easy3D
3D 影像處理函式庫
- 點雲處理與管理
- 靈活的 ZMap 生成功能
- 用於裁切、稀疏化、擬合及對齊點雲的 3D 處理功能
- 相容於多種 3D 感測器
- 透過 3D 檢視器進行互動式 3D 顯示
說明
點雲處理
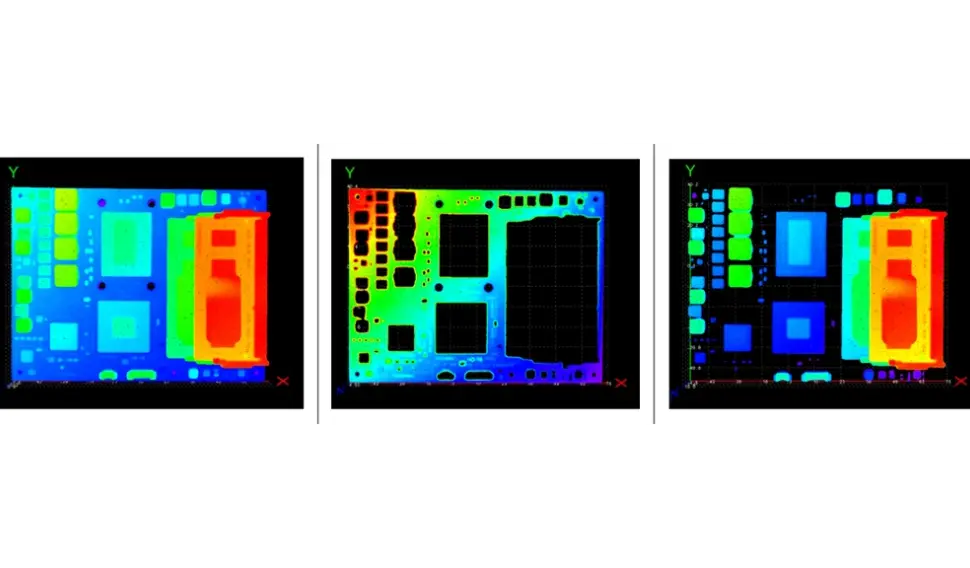
校正完成後,3D 點雲將包含採用真實世界 3D 座標系且無失真的資料。您可以利用 Easy3D 的各項功能來處理 3D 點雲,例如座標變換、點雲裁切與稀疏化、平面偵測與擬合,或是零件對齊。
與 3D 感測器的相容性
Easy3D 函式庫能夠匯入來自 Automation Technology、Azure Kinect、Benano、Heliotis、IDS Ensenso、Intel Realsense、Lucid Helios、LMI Gocator、Mech-Mind、Nerian Ruby、Photoneo PhoXi、 深圳 SinceVision (SSZN)、Zivid 等廠商所提供的資料。該函式庫能高效管理點雲與 ZMap,並支援進行 3D 處理與分析。
ZMap 的生成
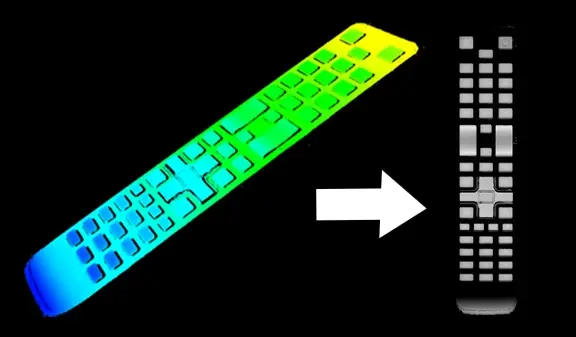
ZMap 是指點雲在參考平面上的投影,其中距離以像素灰階值的形式儲存。ZMap 沒有變形,並採用度量座標系。 Easy3D 提供用於生成此類 ZMap 的函式。更重要的是,您可以將所有 eVision 2D 處理函式套用至 ZMap:透過 EasyImage 進行濾波與閾值處理、透過 EasyObject 進行斑點分析、透過 EasyGauge 進行亞像素測量,以及透過 EasyFind 和 EasyMatch 進行模式配對。
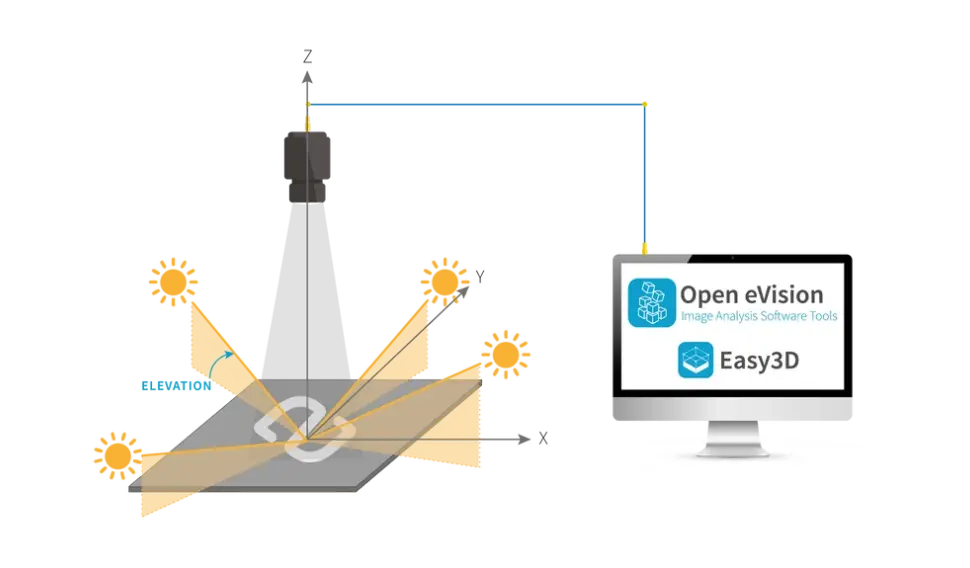
用於 3D 表面檢測的光度立體測量法
「光度立體測量」功能是透過從單一視點拍攝同一表面、但受不同方向光線照射的多張影像,來估算該表面每個點的方位與反照率。 此方法適用於檢查物體表面上那些無法透過單一相機-光源組合所觀察到的細節(缺陷或資訊),並能揭示表面曲率或紋理的細微變化。它可作為其他函式庫的前處理階段,例如:
- 條碼讀取:EasyMatrixCode、EasyQRCode 或 EasyBarCode
- 光學字元辨識:EasyOCR
- 對齊:EasyMatch、EasyFind
- 測量:EasyGauge
- 缺陷檢測:EasyObject、EasySegment
Easy3D 函式庫中提供光度立體測量功能。
3D 檢視器
使用 Easy3D 的 3D Viewer 類別來建立互動式 3D 顯示。3D Viewer 可以顯示點雲和 3D 物件。它使用 OpenGL 介面,並需要相容的顯示裝置。
其他好處
Neo 授權系統
Neo 是一套全新的授權系統。它可靠且技術先進,現已可用於儲存 eVision 和 eGrabber 授權。Neo 讓您能選擇在何處啟用授權,無論是透過 Neo 硬體金鑰,還是 Neo 軟體容器皆可。您先購買授權,之後再決定啟用方式。
Neo 授權金鑰具備堅固的硬體結構,並可靈活地在不同電腦之間移轉。Neo 軟體容器則無需任何專用硬體,而是與其被啟用的電腦綁定。
Neo 隨附專屬的 Neo 授權管理員,提供兩種使用模式:直觀且易於操作的圖形使用者介面,以及可輕鬆自動化 Neo 授權流程的命令列介面。
所有適用於 Windows 與 Linux 的 eVision 函式庫
- Microsoft Windows 11、10 適用於 x86-64 (64 位元) 處理器架構
- Microsoft Windows 11、10 IoT Enterprise 適用於 x86_64 系統
- 適用於 x86-64(64 位元)及 ARMv8-A(64 位元)處理器架構的 Linux,需具備 glibc 2.18 或更高版本
eVision Studio
可透過圖形化介面設計複雜的影像處理流程。這套工具集展現了 eVision 函式庫的多樣性與功能。 對應於處理流程的 C++、Python 及 C# 原始碼會自動產生,並提供 eVision API 的互動式文件。eVision Studio 可處理即時影像來源,例如 GigE Vision 攝影機、Coaxlink 幀擷取卡或 eGrabber 錄影機序列。
此應用程式完全免費,可在 Windows 和 Linux 系統上運行,並相容於 Intel 及 ARM 64 位元架構。
Software
- Host PC Operating System
-
eVision is a set of 64-bit libraries that require an Intel compatible processor with the SSE4 instruction set or an ARMv8-A compatible processor.
eVision can be used on the following operating systems:
Microsoft Windows 11, 10 for x86-64 (64-bit) processor architecture
Microsoft Windows 11, 10 IoT Enterprise for x86-64 systems
Linux for x86-64 (64-bit) and ARMv8-A (64-bit) processor architectures with a glibc version greater or equal to 2.18
Remote connections
Remote connections are allowed using remote desktop, TeamViewer or any other similar software.
Virtual machines
Virtual machines are supported. Microsoft Hyper-V, Oracle VirtualBox and libvirt hypervisors have been successfully tested.
Only the Neo Licensing System is compatible with virtualization.
Minimum requirements:
2 GB RAM to run an eVision application
8 GB RAM to compile an eVision application
Between 100 MB and 2 GB free hard disk space for libraries, depending on selected options.
- APIs
-
Supported programming languages :
The eVision libraries and tools support C++, Python and the programming languages compatible with the .NET (C#, VB.NET)
C++ requirements: A compiler compatible with the C++ 11 standard is required to use eVision
Python requirements: Python 3.11 or later is required to use the Python bindings for eVision
.NET requirements: .NET framework 4.8 (or later) or the .NET platform 6.0 (or later) are supported
Supported Integrated Development Environments:
Microsoft Visual Studio 2017 (C++, C#, VB .NET, C++/CLI)
Microsoft Visual Studio 2019 (C++, C#, VB .NET, C++/CLI)
Microsoft Visual Studio 2022 (C++, C#, VB .NET, C++/CLI)
QtCreator 4.15 with Qt 5.12
Ordering Information
- Product status
-
Released
- Product code - Description
-
PC4181 Open Easy3D for USB dongle
PC4331 Open eVision Easy3D
- Related products
-
PC1637 Coaxlink Quad 3D-LLE
PC6512 eVision/Open eVision USB Dongle (empty)
PC6514 Neo USB Dongle (empty)